Paper accepted in IEICE Transactions on Information and Systems: “DAP”
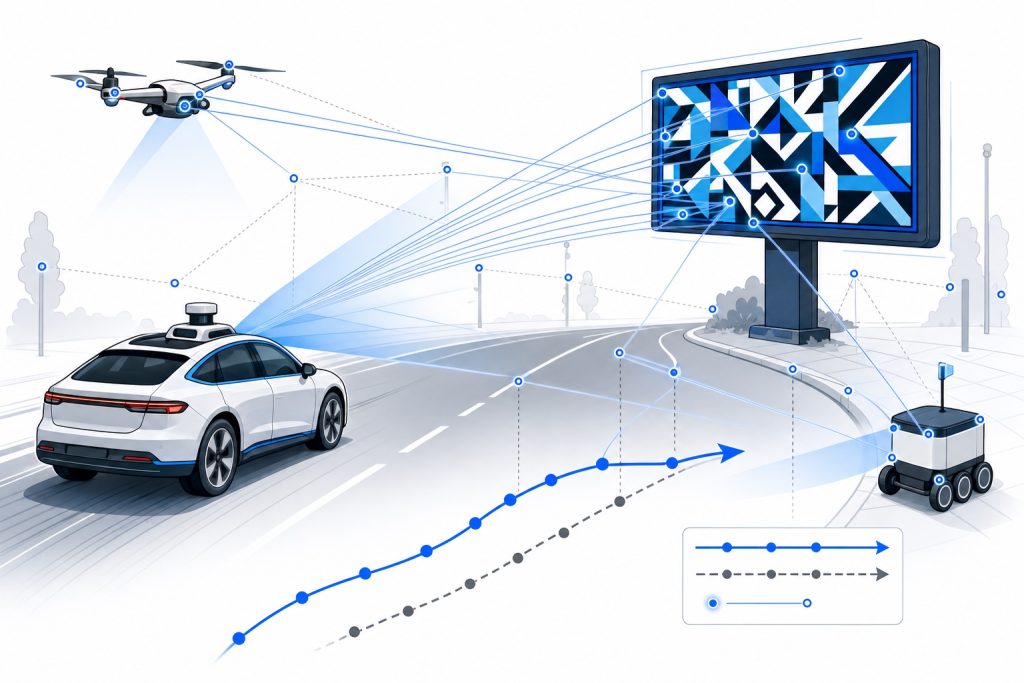
Feature-based visual localization estimates ego motion from tracked visual correspondences and underpins navigation in autonomous vehicles, mobile robots, and drones. Because the recovered pose depends entirely on which correspondences are retained and repeatedly incorporated into optimization, attacker-controlled observations can systematically bias the estimated motion.
In this work, we present DAP (Dynamic Adversarial Patch), a physically realizable attack that induces a controllable pose bias while keeping its attack medium inconspicuous. By displaying dynamically changing content, DAP creates coherent, trackable correspondences that steer pose estimation in an attacker-chosen direction. We analyze the mechanism behind this controllable bias and hide the required feature-inducing structure inside ordinary advertisement content using an environment-adaptive generation pipeline. Evaluated in CARLA and in the real world across representative feature-based pipelines, DAP induces systematic, directional drift with a stable inverse relationship between patch motion and trajectory deviation, and we examine lightweight pipeline-level mitigations that substantially reduce the effect.
[Paper]
Zhihe Zhang, Shuo Peng, Tatsuya Mori, “DAP: Physically Realizable and Controllable Dynamic Adversarial Patch Attack Against Feature-based Visual Localization,” IEICE Transactions on Information and Systems, to appear, June 2027.