University of Florida News features our joint research: simple visual patterns can trick depth perception in vehicles and robots
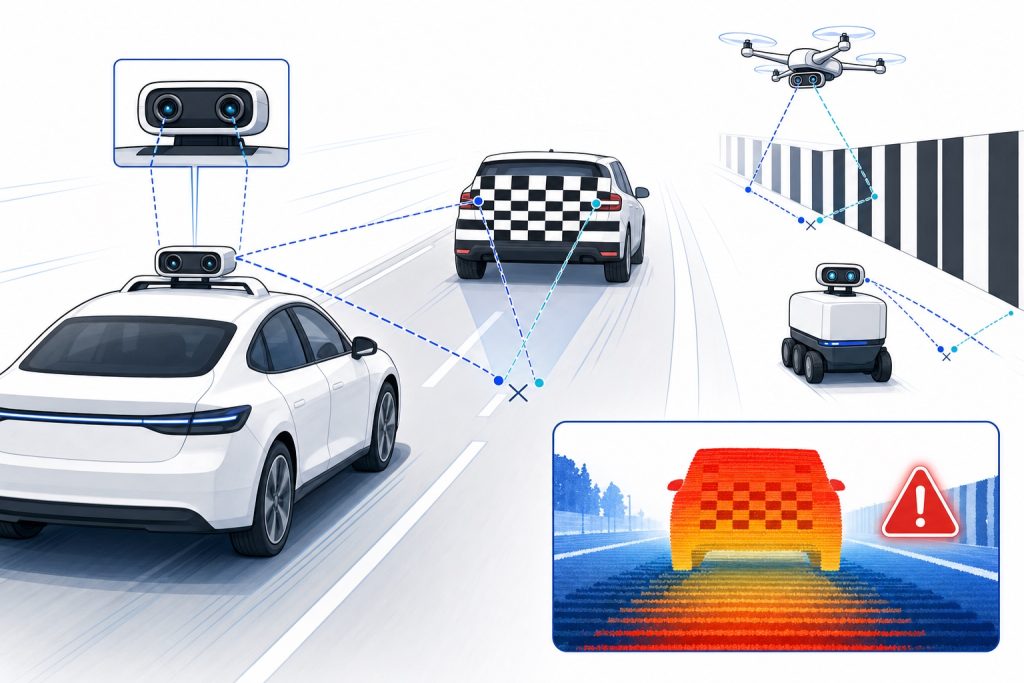
The University of Florida published a news article titled “Simple visual patterns can trick AI-powered vehicles and robots, UF research finds,” introducing the results of our paper “Illusion of Depth,” to be presented at ACM CCS 2026 — a collaboration among the Yoshioka group at Keio University, the Sugawara group at The University of Electro-Communications, and the University of Florida.
The article explains how a simple repeated pattern, such as black-and-white stripes, can cause autonomous vehicles and robots that estimate depth with stereo cameras to misjudge the distance to an obstacle. The weakness is shared by both conventional stereo-matching algorithms and AI models. In a driving scenario, projecting a checkerboard-like pattern onto the back of a vehicle made part of it appear closer than it actually was, enough to trigger an automatic response such as braking. The team also developed defenses that recognize situations involving repeated patterns and prevent incorrect depth estimates. The work has also been covered by Earth.com and TechXplore.
[Paper]
Sri Hrushikesh Varma Bhupathiraju, Tetsu Ishizue, Nicholas U. Costagliola, Ozora Sako, Kentaro Yoshioka, Takeshi Sugawara, Sara Rampazzi, “Illusion of Depth: Revealing Hidden Stereo Vision Vulnerabilities in Depth Estimation,” Proceedings of the ACM SIGSAC Conference on Computer and Communications Security (ACM CCS 2026), The Hague, Netherlands, November 2026.